

Encoder feedback
1000-line encoder for closed-loop operation with a compatible driver.
ELECTRIC MOTORS
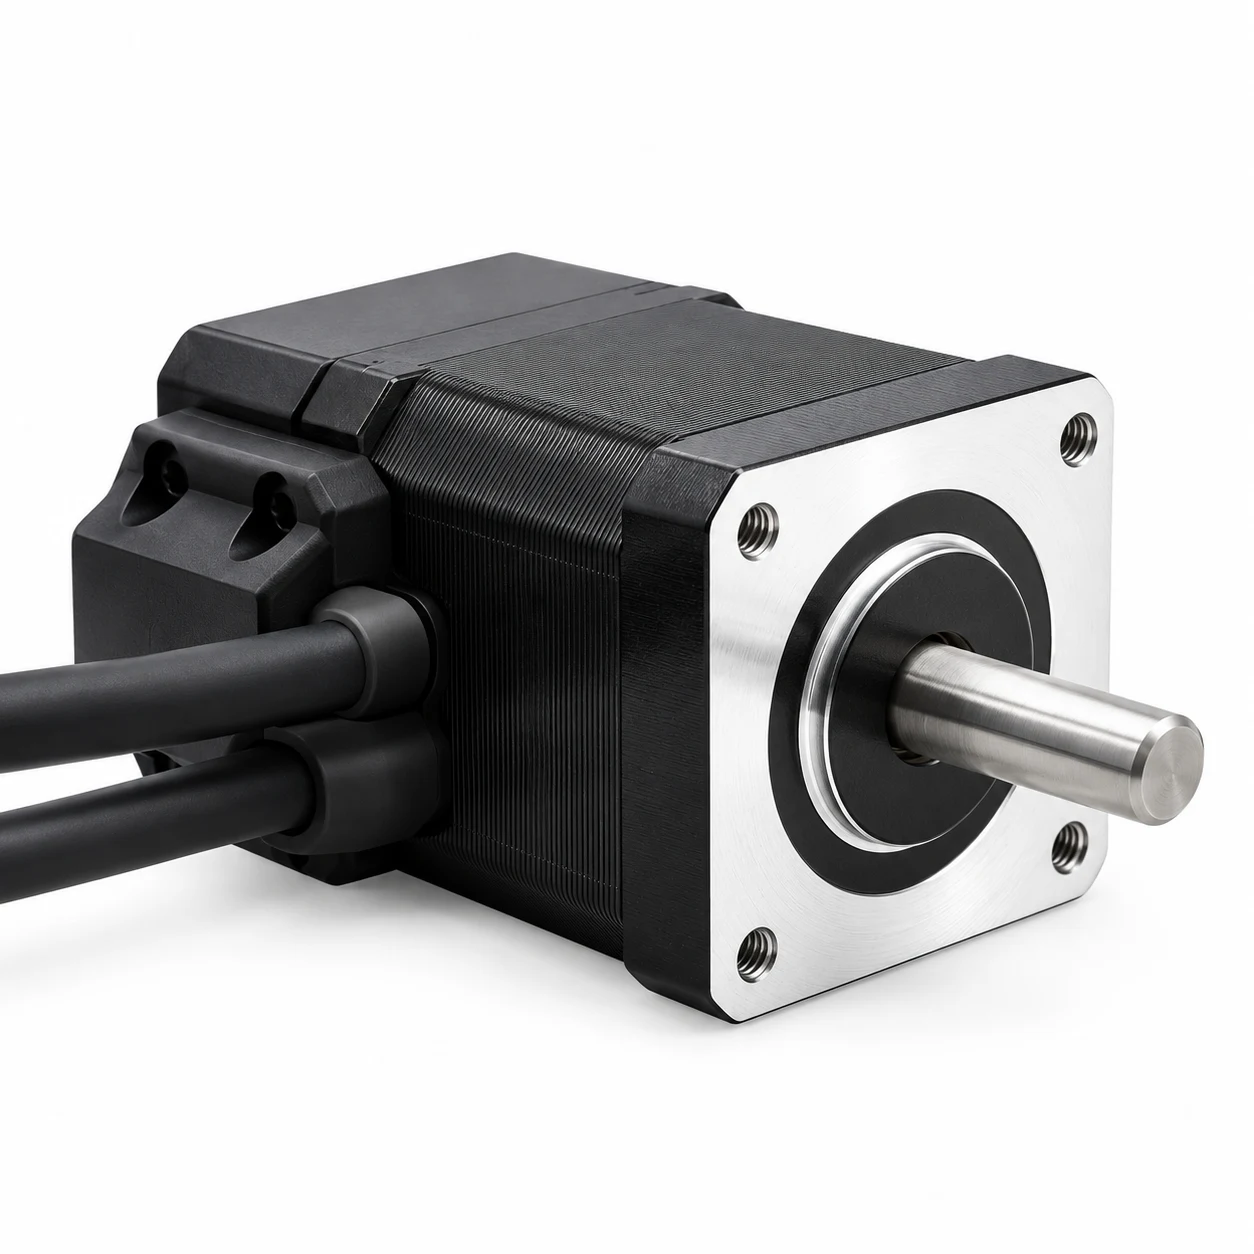
42mm closed-loop stepper motor for precise positioning, feedback control and compact automation equipment.
The 42HSE series combines a 42mm square mounting flange with encoder feedback for closed-loop motion control in compact equipment. Select the body length, holding torque and shaft diameter for your load, available space and drive configuration. Closed-loop operation requires a compatible driver; the supplied catalog lists HSE57.
| Model | Length L (mm) | Holding torque (N·m) | Rated current (A) | Resistance/phase (Ω) | Inductance/phase (mH) | Rotor inertia (g·cm²) | Shaft diameter (mm) | Weight (kg) |
|---|---|---|---|---|---|---|---|---|
| 42HSE33 | 53 | 0.2 | 1.5 | 1.4 | 1.4 | 35 | 5.0 | 0.5 |
| 42HSE33D | 53 | 0.2 | 1.5 | 1.4 | 1.4 | 35 | 8.0 | 0.5 |
| 42HSE38 | 59 | 0.4 | 1.5 | 2.3 | 4.3 | 54 | 5.0 | 0.6 |
| 42HSE38D | 59 | 0.4 | 1.5 | 2.3 | 4.3 | 54 | 8.0 | 0.6 |
| 42HSE47 | 67 | 0.6 | 2.5 | 0.9 | 1.6 | 72 | 5.0 | 0.7 |
| 42HSE47D | 67 | 0.6 | 2.5 | 0.9 | 1.6 | 72 | 8.0 | 0.7 |
| 42HSE60 | 80 | 0.8 | 2.5 | 1.0 | 2.4 | 110 | 5.0 | 0.75 |
| 42HSE60D | 80 | 0.8 | 2.5 | 1.0 | 2.4 | 110 | 8.0 | 0.75 |
Matched driver for all models: HSE57. Shaft flat marking: 0.5 × 15mm. These are representative models; customer-specific designs are available. Final configuration is subject to the approved drawing.
Dimensions in mm. Flange: 42 ± 0.5; mounting-hole pitch: 31 ± 0.2; four M3 mounting holes; pilot diameter: 22; shaft extension: 24 ± 1. Shaft flat dimension: 4.5mm for the 5mm shaft and 7.5mm for the 8mm shaft. Refer to the model table for body length L.
| Motor phase | Wire color |
|---|---|
| A+ | Red |
| A− | Blue |
| B+ | Green |
| B− | Black |
| Encoder pin | Wire color | Signal |
|---|---|---|
| 2 | Red | VCC |
| 3 | White | GND |
| 1 | Black | EA+ |
| 13 | Blue | EA− |
| 11 | Yellow | EB+ |
| 12 | Green | EB− |
The encoder uses a DB15 connector. Verify wiring by pin number rather than connector orientation. Confirm encoder supply voltage against the driver specification; no supply value is stated in the supplied catalog.
The supplied speed–torque curves were measured at 24 VDC. Running torque decreases as speed increases; holding torque is not the available output torque at every speed. Actual performance depends on the driver, supply and load.
Product images are AI-generated visualizations based on the supplied reference. Dimensions and configuration are defined by the specification table and approved drawing.
1000-line encoder for closed-loop operation with a compatible driver.
42mm square flange with four body lengths.
0.2 / 0.4 / 0.6 / 0.8 N·m holding torque and 5mm or 8mm shafts.
shaft, mounting and cable requirements reviewed with professional engineering after-sales support.